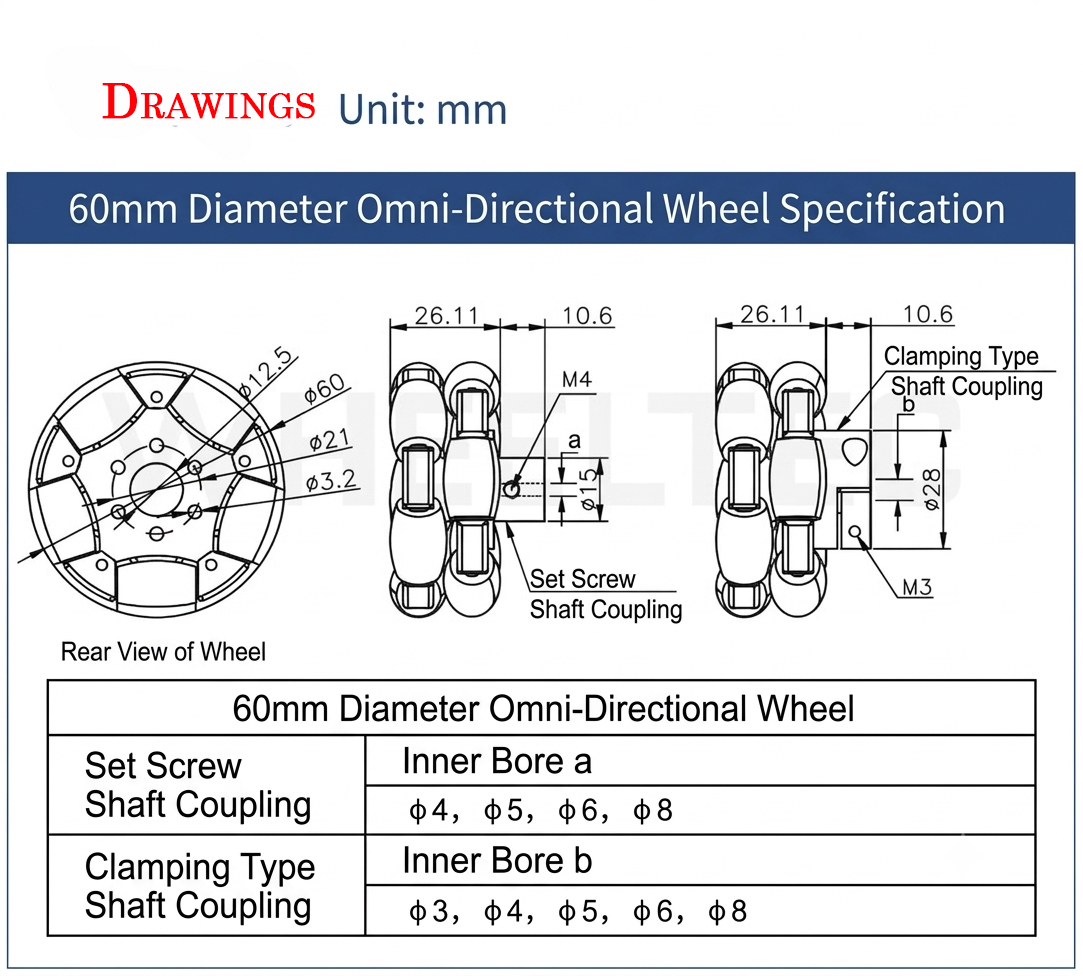
Omni Wheels with Clamp Shaft Mount for Educational & Mobile Robots- 60mm/75mm/127mm
価格帯: $59.00 – $89.00
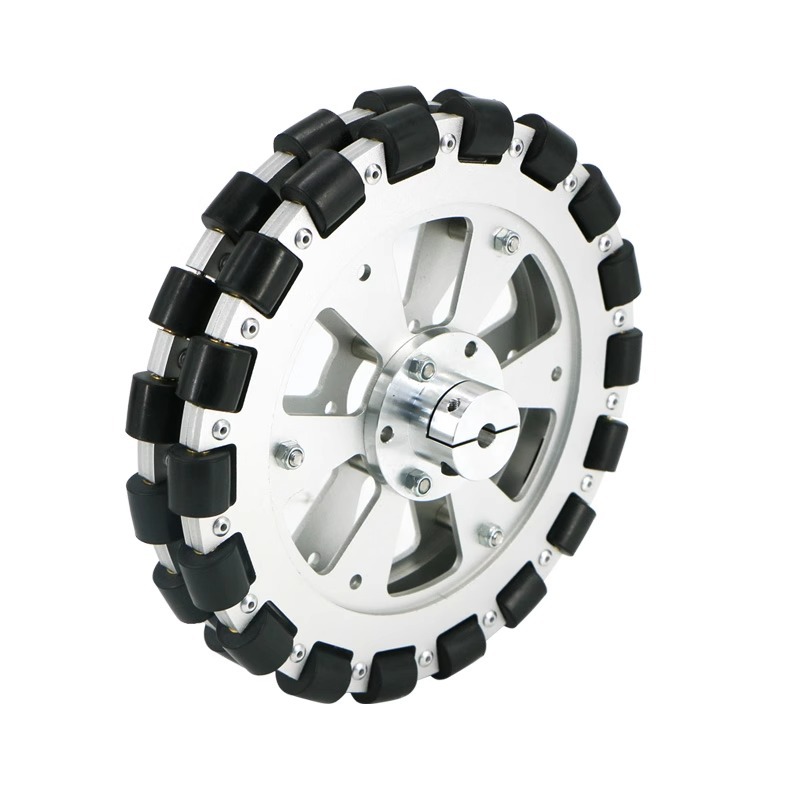
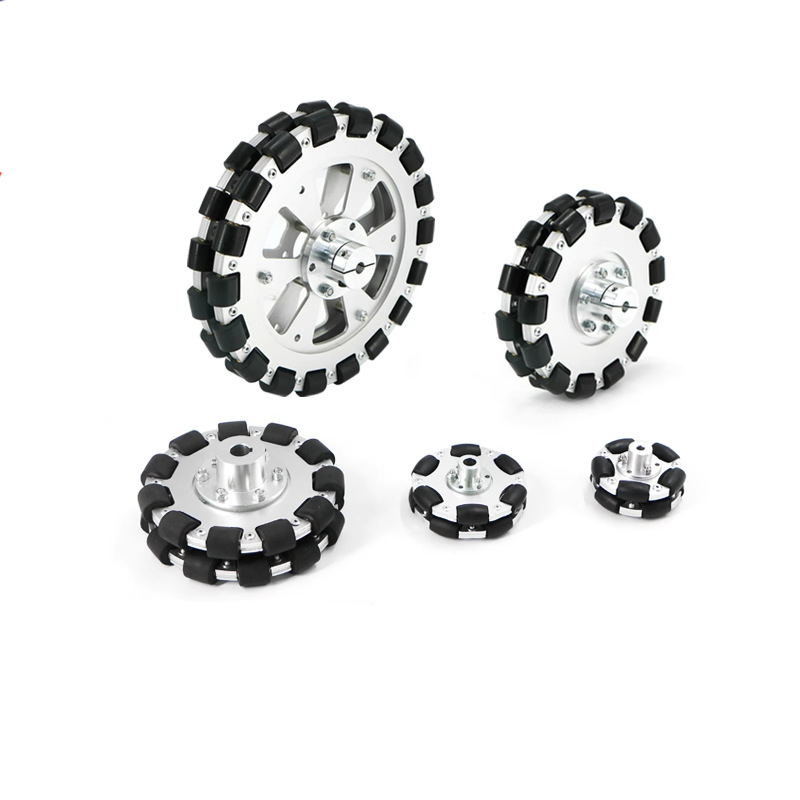
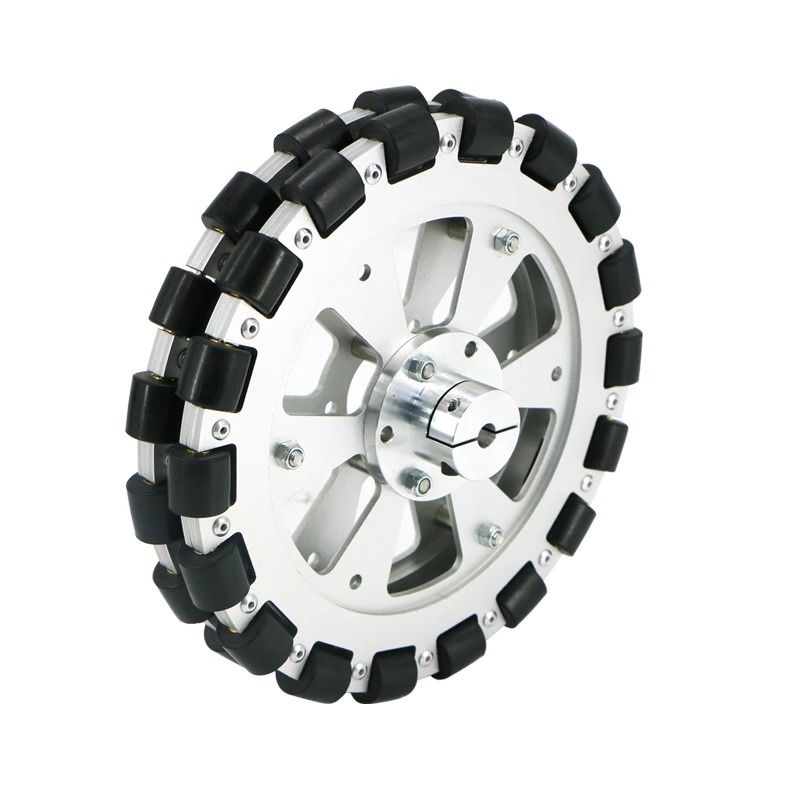
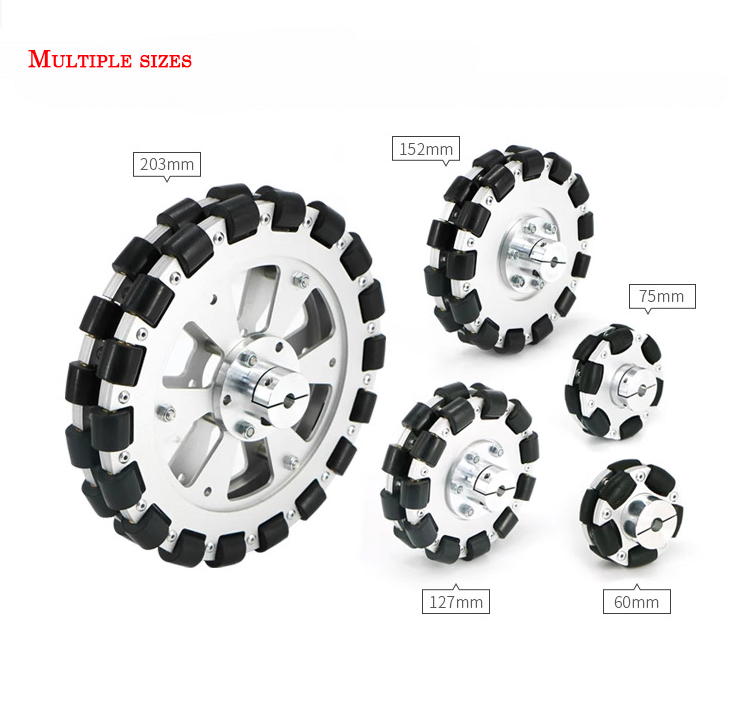
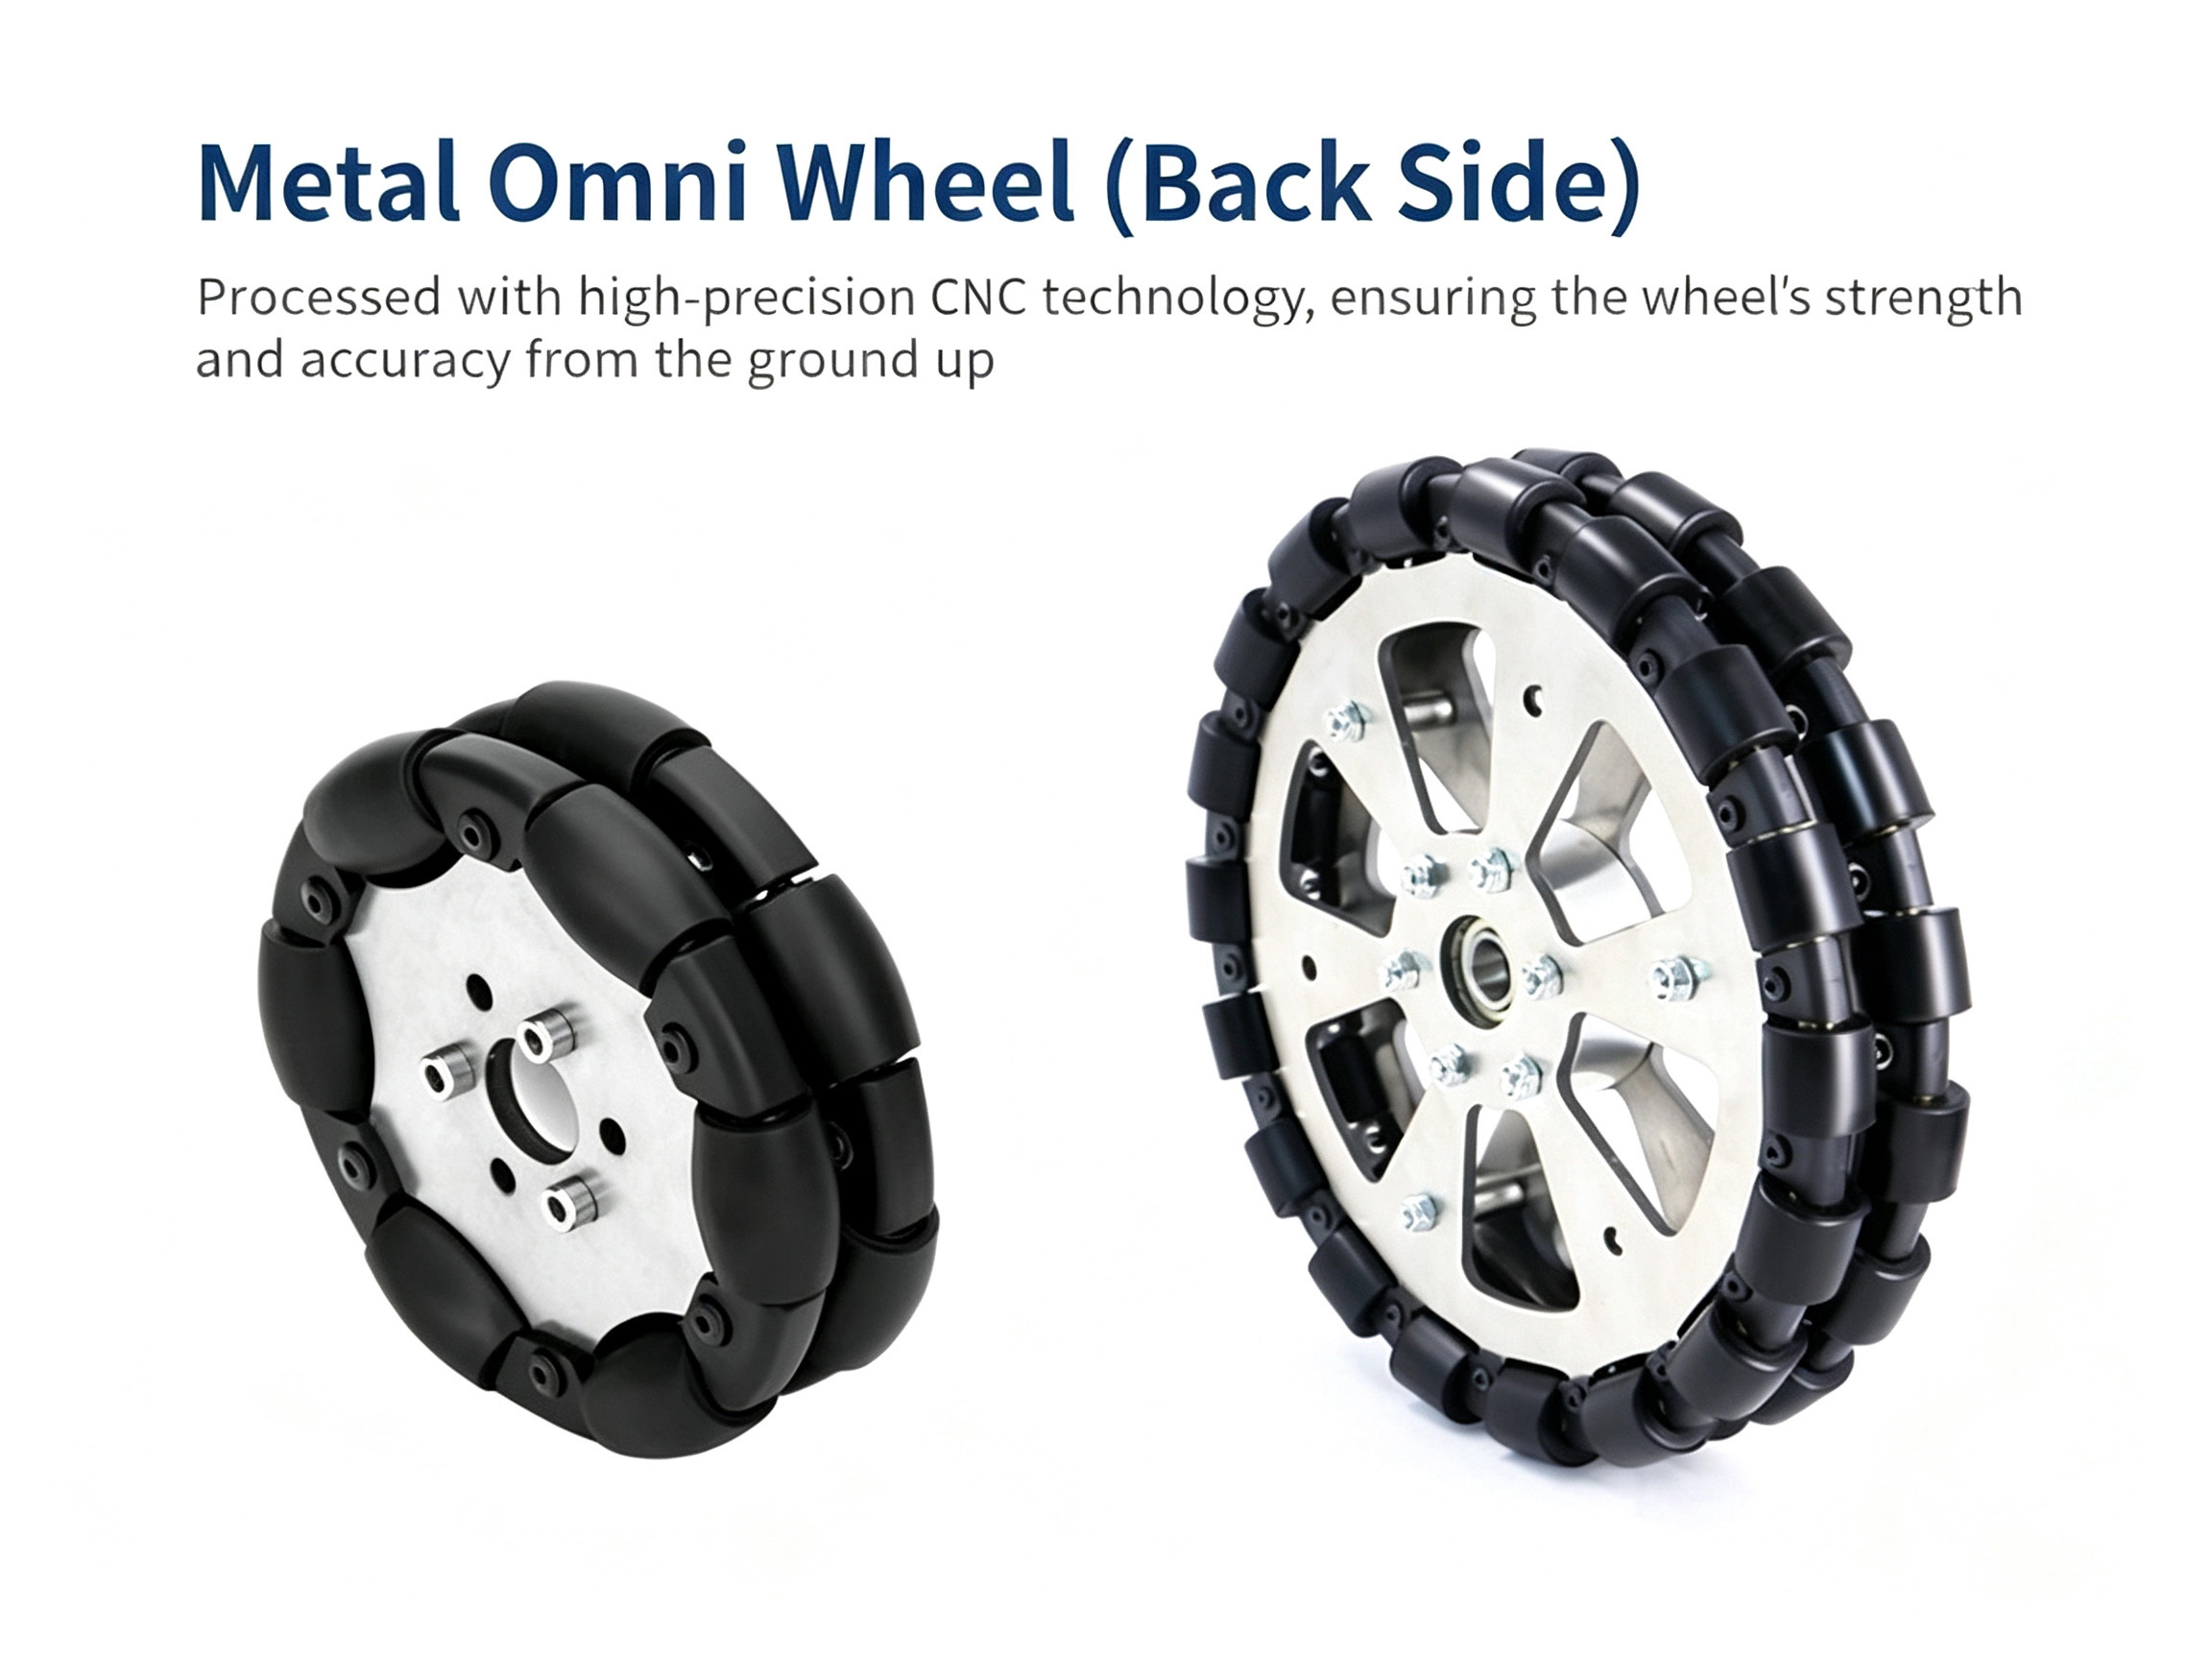
Clamp-Bore Omni Wheels are multidirectional robot wheels designed for educational robots, mobile robots, AGV prototypes and custom robotic platforms. Available in 60mm, 75mm and 127mm diameters with multiple clamping shaft sizes from 3mm to 18mm.
- Wheel diameters: 60mm, 75mm and 127mm
- Clamp-style shaft mounting
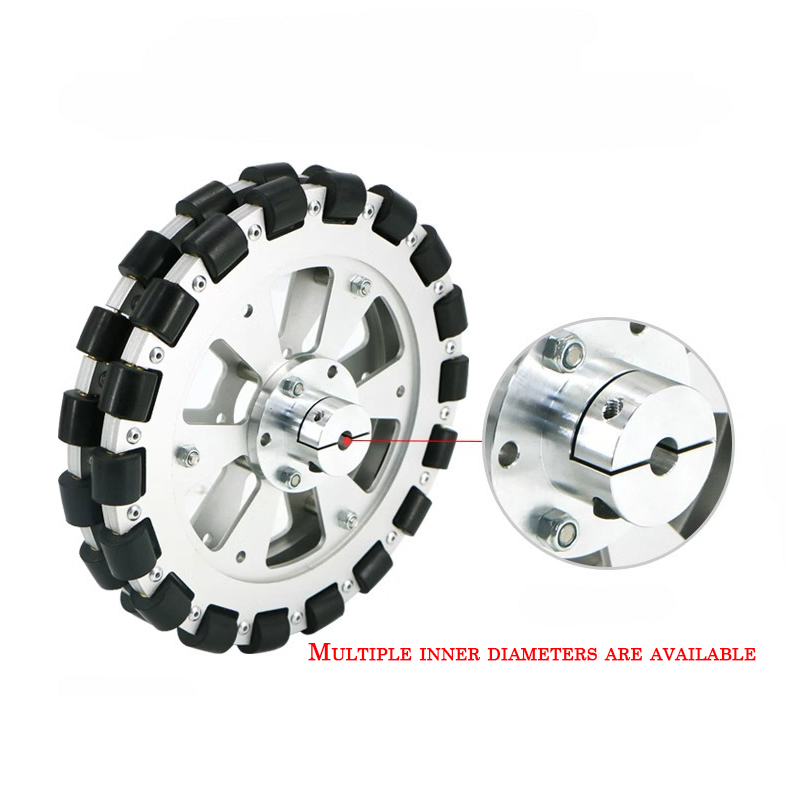
- Multiple shaft bore sizes available
- 24V configurations available
- Designed for multidirectional robot movement
- Suitable for STEM, Arduino, Raspberry Pi and mobile robotics
CAD/STP Files Available – Contact us for engineering drawings.
Discount per Quantity
| Quantity | Discount | Price |
|---|
| 1 - 3 | 0% | $59.00 | |
| 4 - 19 | 10% | 価格帯: $53.10 – $80.10 | |
| 20 + | 20% | 価格帯: $47.20 – $71.20 |
説明
Clamp-Bore Omni Wheels for Mobile Robots
Build compact and highly maneuverable mobile robots with our
Clamp-Bore Omni Wheels. These omnidirectional robot wheels
are designed for robotic platforms that require flexible movement and
multiple shaft mounting options.
Unlike a simple round wheel, an omni wheel uses freely rotating rollers
around the wheel circumference. When combined with an appropriate motor
and drive configuration, multiple omni wheels allow a robot to move
forward, backward, sideways and diagonally.
This series is available in several wheel diameters and clamp-bore
configurations, making it suitable for different robot chassis,
motor shafts and mechanical designs.
Available Wheel Sizes
| Wheel Diameter | Recommended Applications |
|---|---|
| 60mm | Small educational robots, STEM projects, Arduino robots and compact mobile platforms |
| 75mm | Educational robots, smart cars and small autonomous mobile robots |
| 127mm | Larger mobile robots, AGV prototypes and custom robotic platforms |
Clamp-Style Shaft Mounting
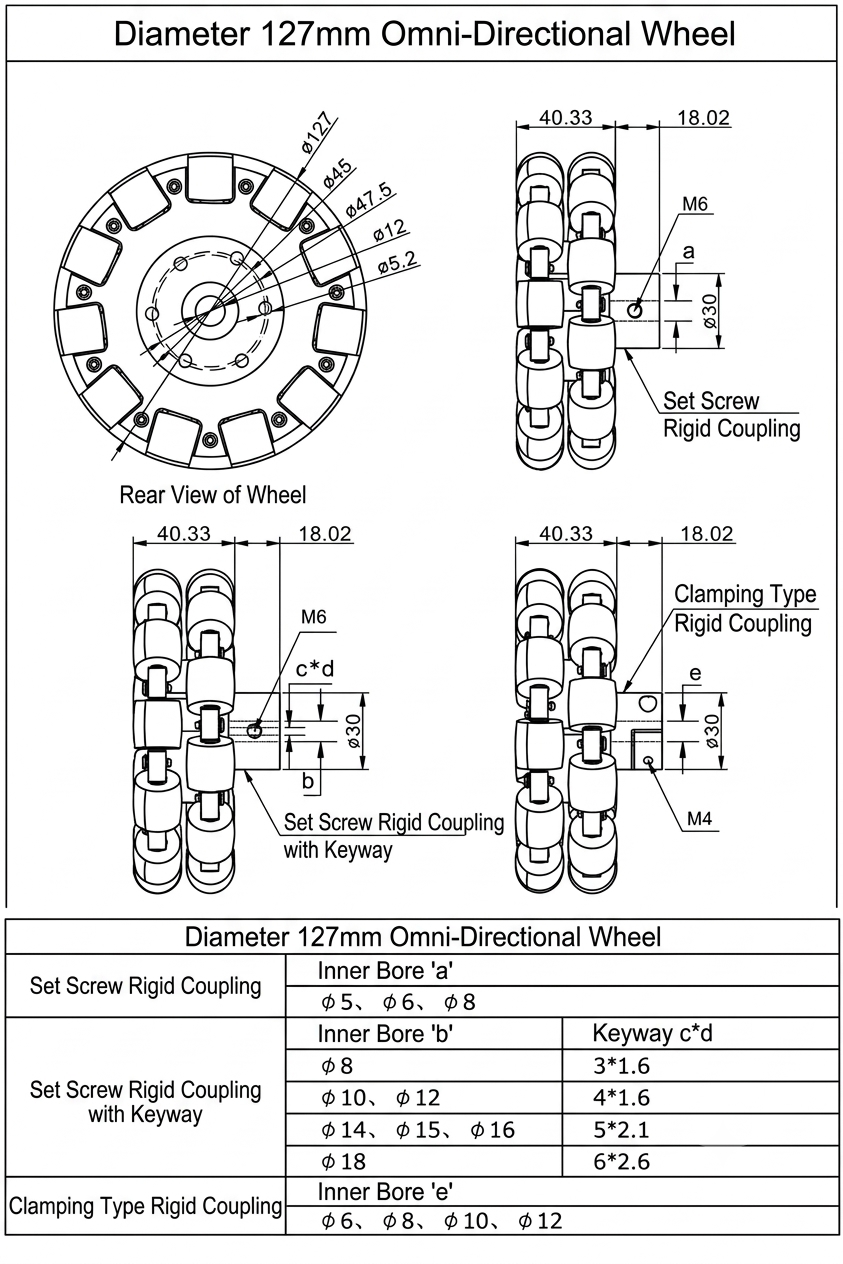
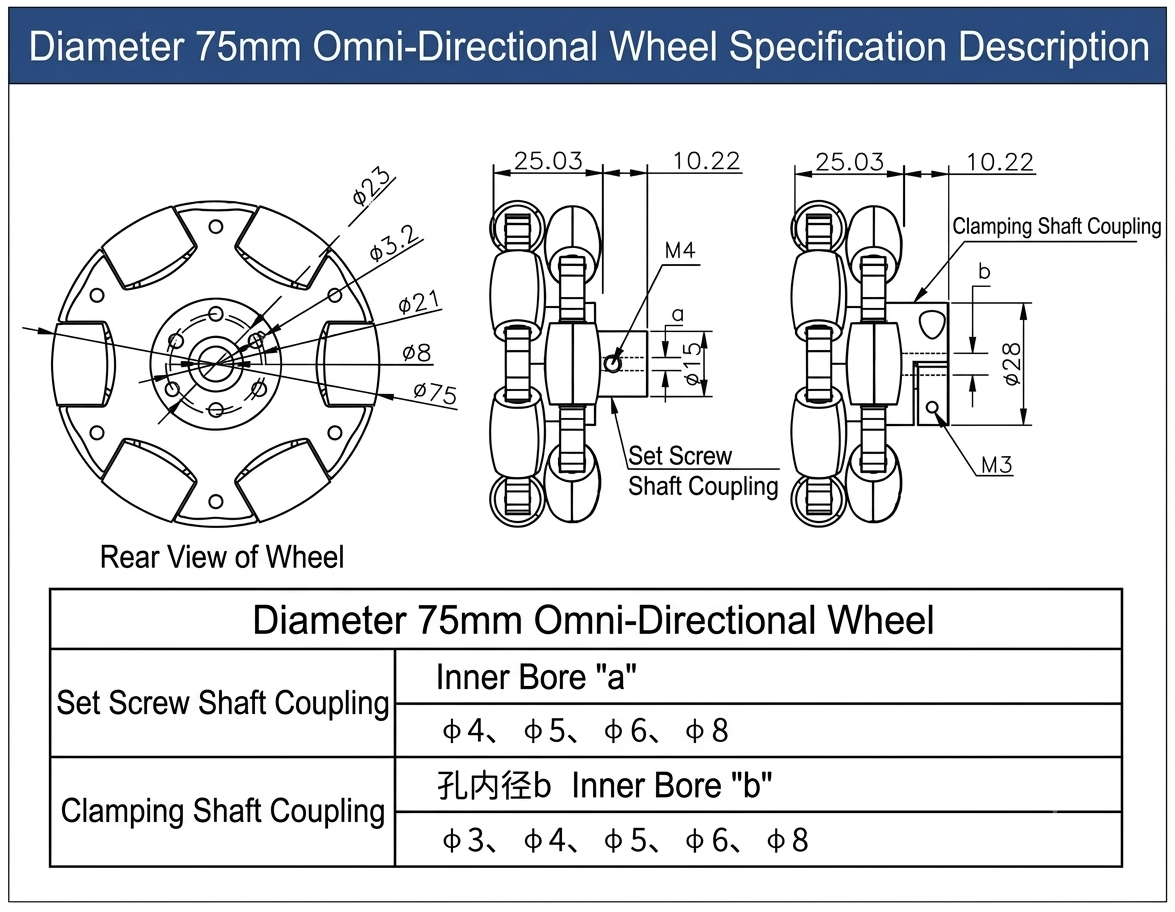
The key feature of this series is the clamp-style shaft mounting
system. Instead of relying only on a traditional keyway, the
clamping mechanism secures the wheel to the motor or drive shaft.
Multiple shaft sizes are available, including configurations from
3mm to 18mm. Please select the correct shaft size according
to your motor shaft diameter before ordering.
configuration. Please confirm your motor shaft size before placing an order.
Designed for Omnidirectional Movement
Omni wheels are commonly used in robotic platforms where conventional
wheels cannot provide sufficient maneuverability.
With the correct multi-wheel drive configuration, a robot equipped with
omni wheels can achieve forward and backward movement as well as lateral
and diagonal movement.
Applications
Educational Robotics
Suitable for STEM education, university projects and robotics development.
Arduino & Raspberry Pi Robots
A practical choice for custom robot cars and programmable mobile robot platforms.
AGV Prototypes
Useful for small AGV and autonomous mobile robot prototypes requiring multidirectional movement.
Custom Mobile Robots
Suitable for research robots, service robots, smart vehicles and custom robotic platforms.
Why Choose Clamp-Bore Omni Wheels?
- Multiple diameters: 60mm, 75mm and 127mm options.
- Multiple shaft sizes: Clamp configurations from 3mm to 18mm.
- Secure shaft mounting: Clamp-style mounting helps connect the wheel to compatible motor shafts.
- Multidirectional movement: Suitable for omnidirectional robot drive systems.
- Flexible applications: Designed for STEM, mobile robotics and AGV prototypes.
- 24V options: Selected configurations are available for 24V robotic systems.
How to Select the Correct Omni Wheel
- Choose the wheel diameter.
Select 60mm, 75mm or 127mm according to your robot chassis and required ground clearance. - Measure your motor shaft.
Confirm the actual shaft diameter before selecting the clamp-bore size. - Check the robot load.
Consider the total robot weight and load distribution when selecting your wheel configuration. - Check your drive layout.
The number and arrangement of omni wheels determine the movement capabilities of the robot.
Need Help Choosing the Right Configuration?
Not sure which omni wheel fits your robot?
Send us your motor model, shaft diameter, robot weight and required wheel diameter.
We can help you identify a suitable configuration.
Looking for clamp-bore omni wheels for an Arduino, Raspberry Pi,
AGV or custom mobile robot? Contact OmniWheelPro for configuration
and quantity inquiries.
追加情報
| Model | Omni A 60mm, Omni A 75mm, Omni A 127mm |
|---|---|
| Clamp Coupling Size | Clamp Coupling 3mm, Clamp Coupling 4mm, Clamp Coupling 5mm, Clamp Coupling 6mm, Clamp Coupling 8mm, Clamp Coupling 10mm, Clamp Coupling 12mm, Clamp Coupling 14mm, Clamp Coupling 15mm, Clamp Coupling 16mm, Clamp Coupling 18mm |
関連商品
-
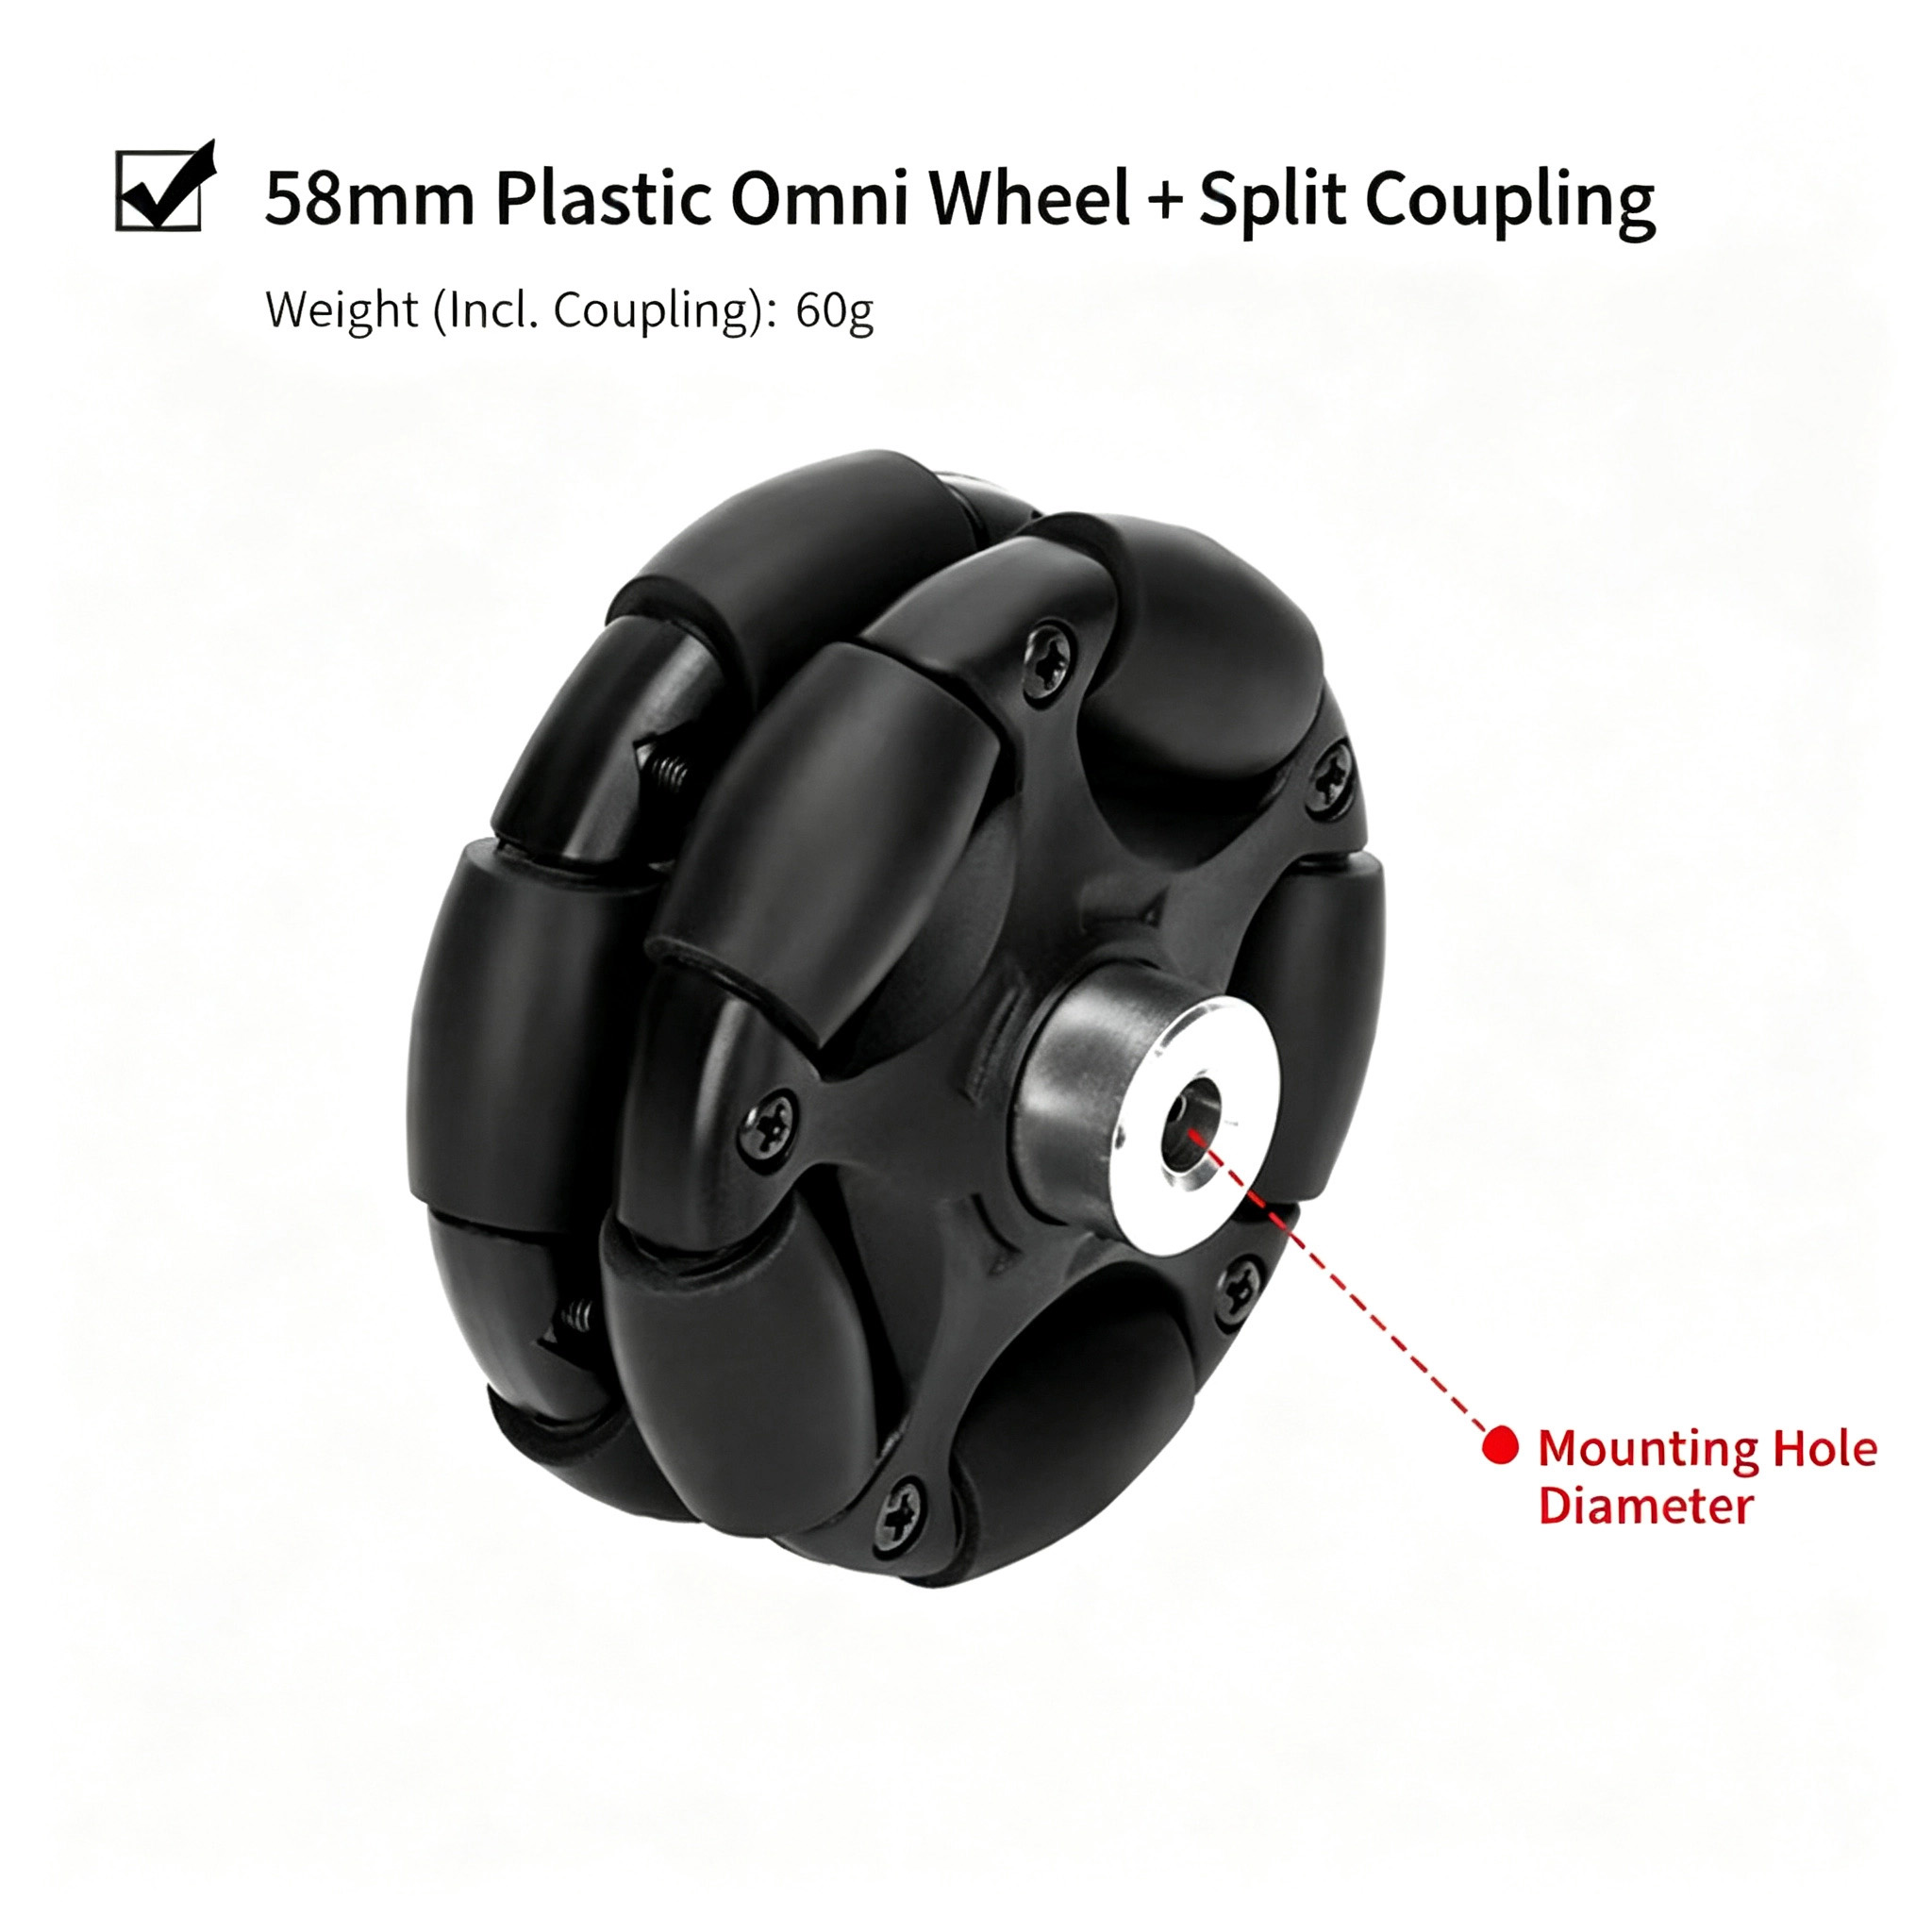
58mm 12V Motorized Plastic Omni Wheel for Educational Robots
58mm Motorized Plastic Omni Wheel designed for educational robots, STEM projects, DIY robot cars, Arduino and Raspberry Pi robotics platforms. Available with 3mm, 4mm, 5mm, or 6mm internal diameter couplers for different motor shaft configurations. Powered by a 12V, 1A motor, this compact omni wheel provides flexible multi-directional movement for small robotic platforms and educational applications. CAD/STP Files Available – Contact us for engineering drawings. 価格帯: $23.98 – $29.98 -
A-Series Omni Wheels for Educational & Mobile Robots- 60mm/75mm/127mm 24V
A-Series Omni Wheels are compact multidirectional robot wheels designed for educational robots, smart cars, AGV prototypes, and other mobile robotic platforms. Available in multiple wheel diameters from 60mm to 127mm with different shaft mounting configurations.- Wheel diameters: 60mm, 75mm, 127mm, 152mm, 203mm
- Multiple shaft mounting options
- Designed for multidirectional robot movement
- Suitable for STEM and educational robotics
- Ideal for mobile robots, AGV prototypes and smart vehicles
- 24V configurations available for compatible powered setups
-
70mm / 85mm Plastic Omni Wheel with Clamp-Type Coupler for Smart Robots 12V
The 70mm / 85mm Plastic Omni Wheel with Clamp-Type Coupler is designed for smart robots, educational robots, DIY robot cars, STEM projects, and compact mobile robotic platforms. Featuring an omni-directional wheel design and a clamping shaft coupler, this robot wheel provides a convenient way to connect the wheel to a compatible motor shaft. Available in 70mm and 85mm diameter options. CAD/STP Files Available – Contact us for engineering drawings. 価格帯: $26.38 – $40.98
 Japanese
 English
レビュー
There are no reviews yet